R-LEAF is an agricultural and field robotics research group at INRAE, within the Technologies and Information Systems for Agroecosystems (TSCF) research unit in Aubière, near Clermont-Ferrand, France.
Recent publications
All publications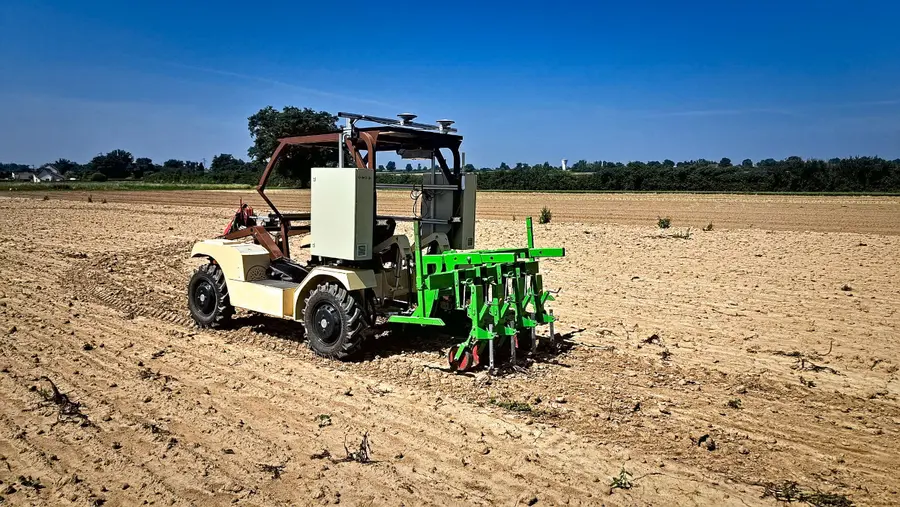
A Predictive Control Strategy to Offset-Point Tracking for Agricultural Mobile Robots
Keeping an agricultural tool on its path while the robot moves.
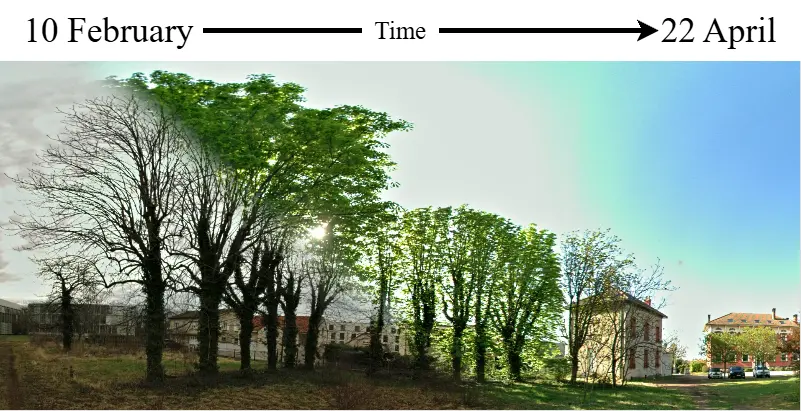
When and Where Localization Fails: An Analysis of the Iterative Closest Point in Evolving Environment
How changes in an outdoor scene affect lidar-based localization.
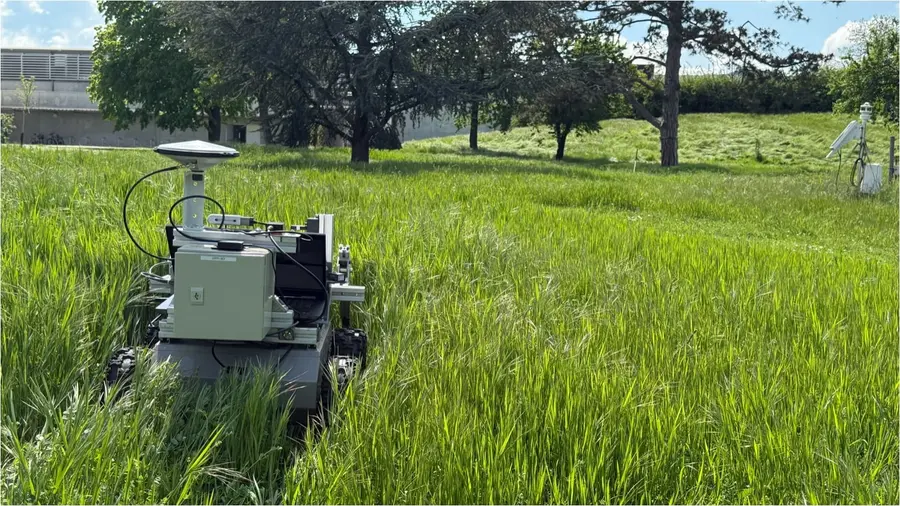
Feeling the Force: A Nuanced Physics-based Traversability Sensor for Navigation in Unstructured Vegetation
Measuring the resistance of vegetation with a force sensor mounted on a robot.