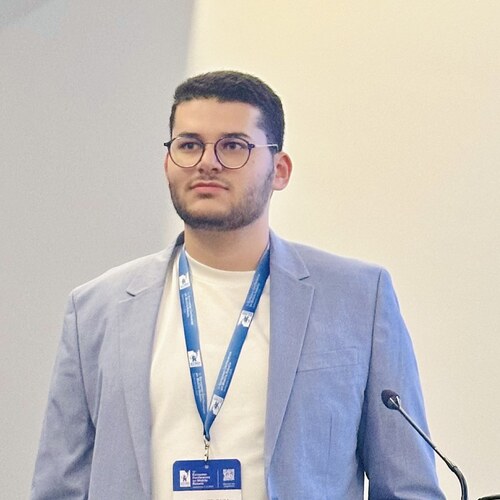
Mohamed Ounally is a Ph.D. student at INRAE and Université Clermont Auvergne, in the R-LEAF team of the TSCF research unit. He works on control, mapping and robot motion in natural environments. He graduated top of his class in the Master’s programme in Automatic Control and Robotics at Université Clermont Auvergne in 2026, specializing in Artificial Perception and Robotics.
Current research
His doctoral project concerns the coordination of an agricultural robot and its tool. The aim is to control the point where the tool acts on the crop or soil, while respecting the constraints of the platform and its actuators. Mechanical weeding and localized interventions are the first applications considered. This work is supervised by Johann Laconte, Roland Lenain, Riccardo Polvara and Florian Rançon.
His research interests also include mapping and state estimation, with an emphasis on the measurements and motion models needed for control in the field.
Previous research
At INRAE in 2025, he developed ROS 2 software for the Unitree B1 quadruped and studied the influence of slope and heading on energy consumption. This work led to an energy prediction model evaluated in outdoor experiments.
In 2026, he worked with INRAE and the Northern Robotics Laboratory at Université Laval on the MTT-154, an articulated tracked vehicle. He developed its ROS 2 control and measurement software, integrated lidar- and GNSS-based mapping and teach-and-repeat navigation, and carried out field trials. He also worked on calibration, trajectory reconstruction and motion modelling, including the implementation and evaluation of a model accounting for the extent of track contact with the ground. The resulting studies on contact-aware motion prediction and inertial steering are available as preprints.
Teaching
He teaches at Université Clermont Auvergne, ISIMA and IUT Clermont Auvergne, in subjects related to robotics, control and programming.
Publications
2026
- Ounally, M. D., Samson, N., Turgeon-Roy, M., Vannini, V., Laconte, J., & Pomerleau, F. (2026). Steering Through Contact: A Finite-Support Motion Model for Single-Track Center-Articulated Robots. arXiv Preprint arXiv:2609.23271. https://doi.org/10.48550/arXiv.2609.23271
arXiv
DOI
BibTeX
@article{ounally2026steering, title = {Steering Through Contact: A Finite-Support Motion Model for Single-Track Center-Articulated Robots}, author = {Ounally, Mohamed Dhia and Samson, Nicolas and Turgeon-Roy, Mathis and Vannini, Veronica and Laconte, Johann and Pomerleau, François}, journal = {arXiv preprint arXiv:2609.23271}, year = {2026}, arxiv = {https://arxiv.org/abs/2609.23271}, doi = {10.48550/arXiv.2609.23271} } - Turgeon-Roy, M., Ounally, M., Vannini, V., Roy, O., & Pomerleau, F. (2026). Inertial Steering and Motion Prediction of Tracked Vehicles on Low-Adherence Surfaces. arXiv Preprint arXiv:2610.38888. https://doi.org/10.48550/arXiv.2610.38888
arXiv
DOI
BibTeX
@article{turgeonroy2026inertial,
  title = {Inertial Steering and Motion Prediction of Tracked Vehicles on Low-Adherence Surfaces},
  author = {Turgeon-Roy, Mathis and Ounally, Mohamed and Vannini, Veronica and Roy, Olivier and Pomerleau, François},
  journal = {arXiv preprint arXiv:2610.38888},
  year = {2026},
  arxiv = {https://arxiv.org/abs/2610.38888},
  doi = {10.48550/arXiv.2610.38888}
}
2025
- Ounally, M., Pierre, C., & Laconte, J. (2025). Energy Prediction on Sloping Ground for Quadruped Robots. 3D-Advice: Advanced 3D Vision for Complex Environments Workshop. https://arxiv.org/abs/2603.11963
arXiv
HAL
PDF
Project
BibTeX
@inproceedings{ounally2025energy,
  hal = {https://hal.science/hal-05568205v1},
  arxiv = {https://arxiv.org/abs/2603.11963},
  url = {https://arxiv.org/abs/2603.11963},
  pdf = {/assets/papers/energy_prediction_slopes_2025.pdf},
  title = {Energy Prediction on Sloping Ground for Quadruped Robots},
  author = {Ounally, Mohamed and Pierre, Cyrille and Laconte, Johann},
  booktitle = {3D-Advice: Advanced 3D Vision for Complex Environments Workshop},
  year = {2025},
  organization = {IEEE},
  address = {Padua, Italy}
}